Senior Engineer L1 · FEV India (Humanoids & Sim-to-Real)
Pune / Mumbai, India

Tejas Phutane

Senior Robotics & Computer Vision Engineer specialized in humanoid platforms, sim-to-real locomotion policies, and real-time edge perception.

Over 4+ years architecting and shipping production-grade robotics — currently developing bipedal locomotion policies, safety layers, and sim-to-real transfer for the Unitree G1 humanoid at FEV India. Proven track record deploying sub-50ms TensorRT perception pipelines on factory floors, commissioning 7+ robotic platforms at Gujarat Science City, and engineering aerospace vision systems with DRDO/ADA.

4+Years Production Robotics
7+Robotic Platforms Deployed
80%Compute Overhead Reduced
Sub-50msEdge Perception Latency
View Engineering ProjectsResume / CV
CORE HARDWARE & COMPUTE STACK:
ROS 2C++20Unitree G1NVIDIA Isaac SimDeepStreamTensorRTJetson AGX
SYS_ID // TP-ROB-01G1 HUMANOID // SIM-TO-REAL
Tejas Phutane — Senior Robotics & Computer Vision Engineer

About

From College Labs to Production Floors

I'm a Senior Engineer L1 currently at FEV India, actively developing humanoid robotic systems on platforms like the Unitree G1 with Inspire dexterous hands. With 4+ years of hands-on experience, I design physics-accurate sim-to-real transfer workflows, bipedal locomotion policies, and robust hardware abstraction/safety layers that bring complex robots reliably into reality.

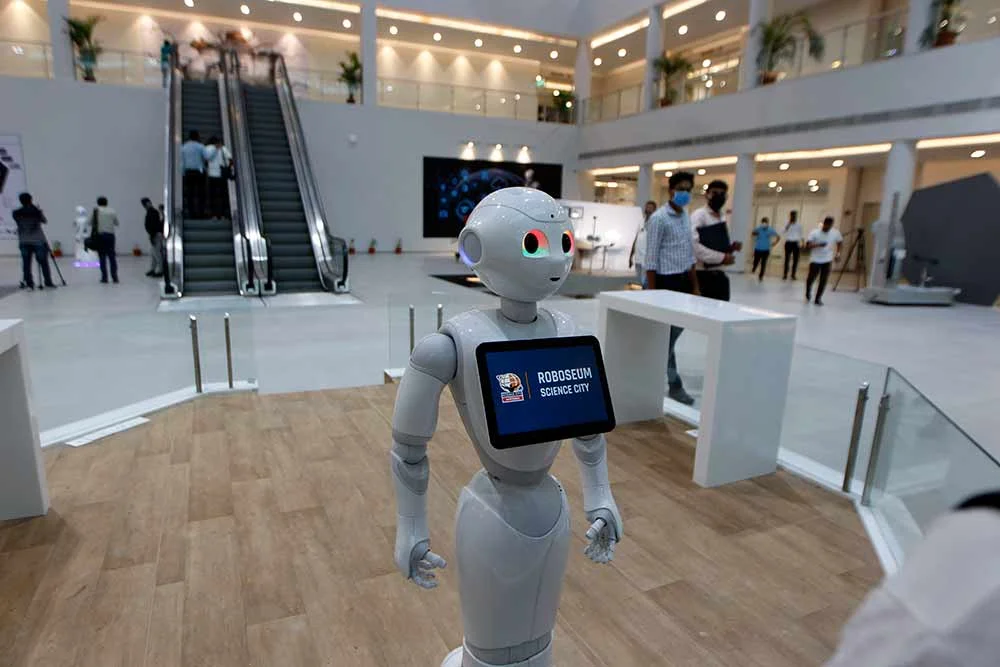
My journey started at RGIT's Robotics Club in Mumbai, where I led simulation and trained 50+ students. From there, I contributed to India's first Robotics Gallery at Gujarat Science City — working hands-on with Pepper humanoids, UR10 arms, Da Vinci surgical robots, SCARA systems, and autonomous mobile platforms.

At Wastefull Insights, I scaled from robotics engineer to senior engineer, architecting autonomous waste sorting systems that process 10,000+ objects daily. I refactored Python to C++ for 80% compute reduction, built multi-model YOLO pipelines with DeepStream, and developed analytics frameworks with 91% throughput prediction accuracy.

The theme has been consistent: take messy real-world problems and convert them into reliable, measurable systems.
Education

B.E. Electronics & Telecommunication

RGIT Mumbai (2017-2021) · CGPA: 7.04

Currently

Senior Engineer L1 at FEV India Pvt Ltd

Unitree G1 Humanoid & Inspire Hand

Key Achievements

  • 40% speed improvement in motion algorithms
  • 80% computational reduction (Python → C++)
  • 91% throughput prediction accuracy
  • 99%+ detection accuracy in production

Engineering Tenets

Delivering Real-World Value vs Conceptual Demos

Moving robotics from fragile Jupyter notebook prototypes into 24/7 industrial factory deployment requires solving the messy realities of hardware, compute, and physical environments.

Low-Latency Edge Determinism

C++ / CUDA / TensorRT Engines

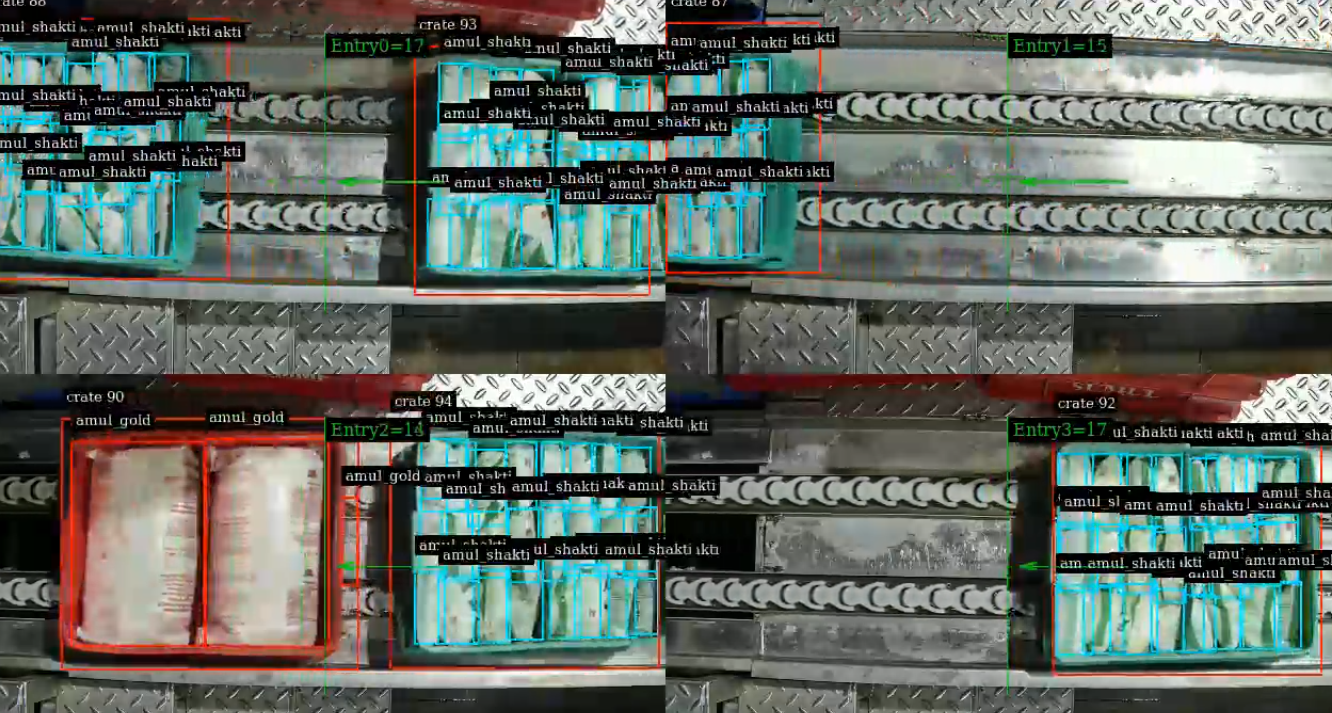
Research prototypes in Python break down under sub-30ms industrial control cycles. I refactor critical perception bottlenecks to multithreaded C++ and serialize deep learning models into TensorRT FP16/INT8 engines on NVIDIA Jetson Xavier, slashing compute overhead by 80% while concurrently processing 4 RTSP feeds.

⚡ 80% Compute Overhead Reduced · Sub-50ms Latency

Factory-Floor Ruggedness

24/7 Optical, Thermal & Vibration Robustness

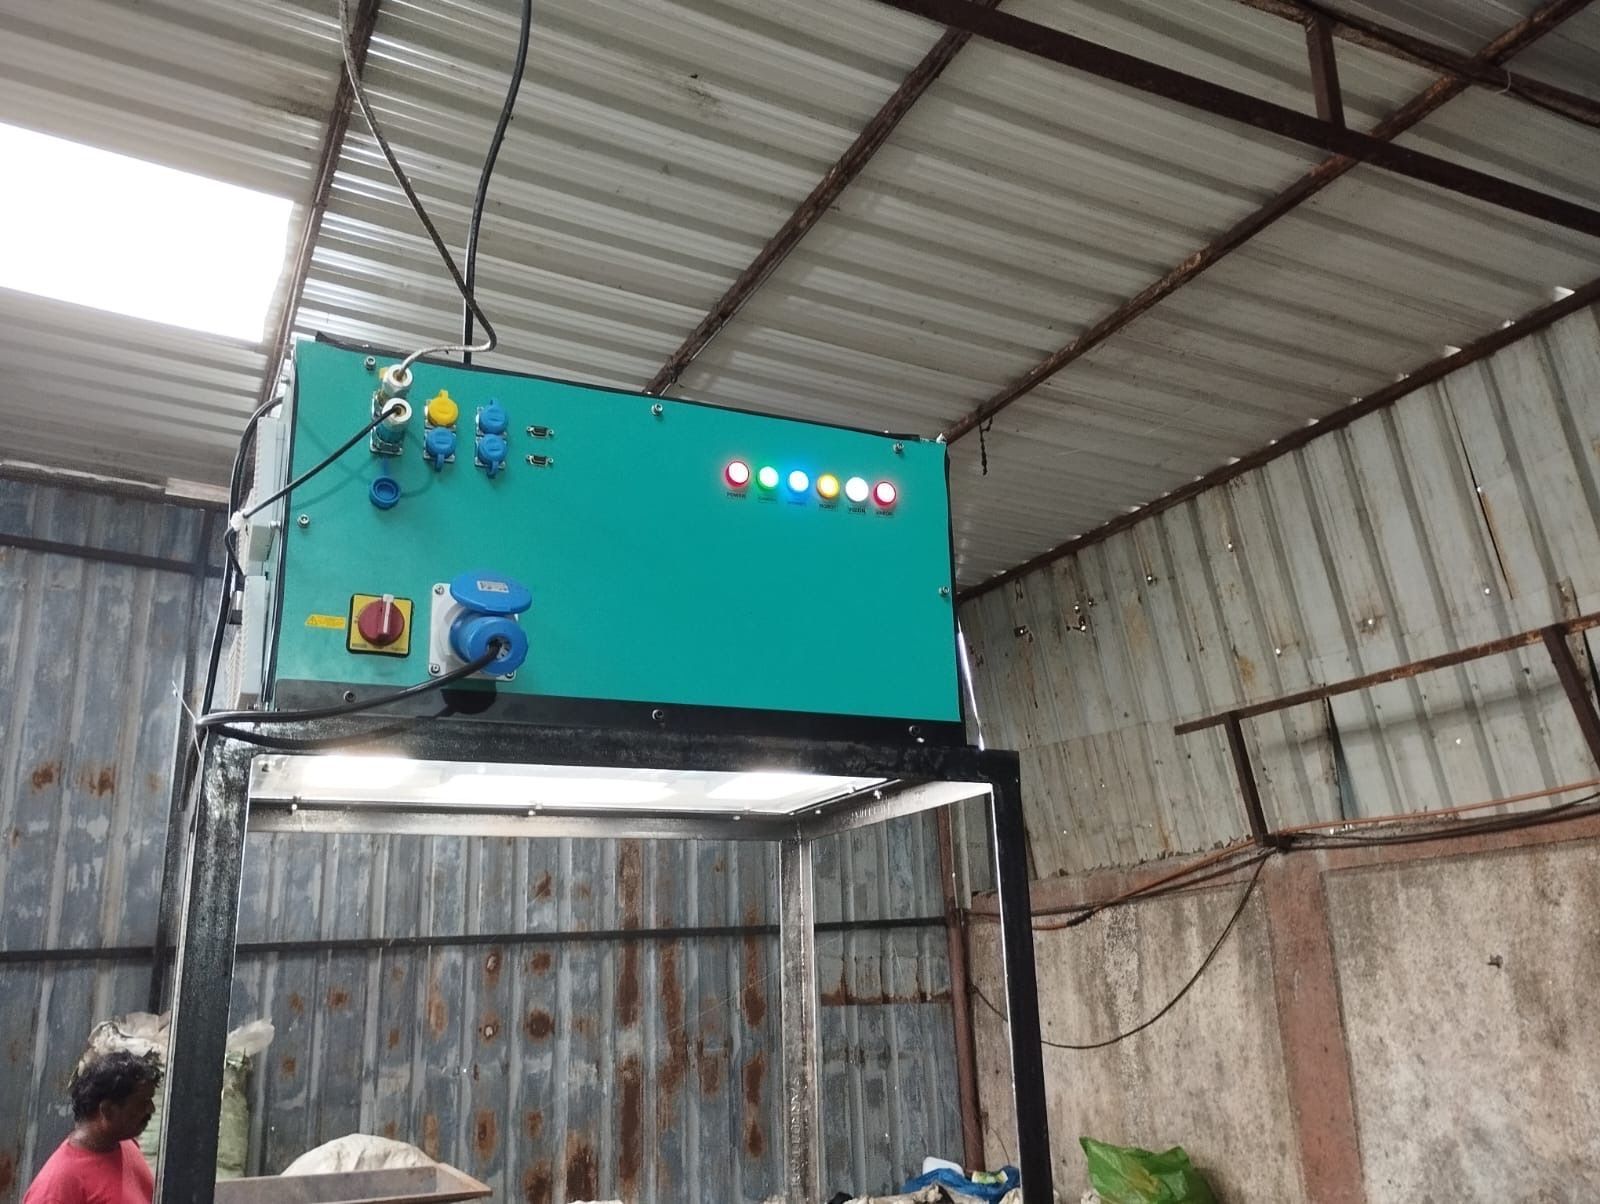
True delivery means engineering for dust, camera vibration, and ambient factory lighting swings. I design industrial GigE line-scan vision setups, integrate synchronized strobe lighting, program Omron PLC safety interlocks, and architect watchdog auto-recovery loops ensuring 99.2%+ operational consistency.

🛡️ 99.2% Detection Accuracy · PLC Safety Handshakes

Mechatronic & Motion Optimization

Mathematical Cycle-Time Reduction

In production pick-and-place, milliseconds directly dictate facility throughput. By mathematically modeling and refining 3-axis gantry acceleration and S-curve motion profiles, I eliminated inertial losses by 15% and boosted picking cycle speed by 40%, coordinating multi-robot cells sorting 10,000+ items daily.

⚙️ 40% Cycle Speed Boost · 10,000+ Daily Objects

Quantified Business ROI

Fleet Telemetry & Predictive Analytics

Robotics engineering must produce verifiable economic impact. I built end-to-end telemetry pipelines streaming real-time vision analytics through Kafka and TimescaleDB, training regression models that predict facility throughput with 91% accuracy and slashing manual quality inspection labor by 60%.

📊 60% Labor Reduction · 91% Prediction Precision

What I'm Exploring Next

Pushing the boundaries of what robots can perceive, plan, and execute.

Physical AI & Synthetic Data

Exploring simulation environments like Isaac Sim Arena, RoboStudio, GenieSim, and Lightwheel AI (RoboFinals) to generate physics-grounded synthetic data for humanoid policy training.

Egocentric Data Collection Pipelines

Developing first-person multimodal demonstration pipelines (egocentric vision, tactile, proprioception) on platforms like RoboLab for dexterous manipulation and imitation learning.

Model Training & Validation Layers

Engineering closed-loop verification benchmarks and diagnostic safety boundaries to evaluate policy stability before running on physical humanoid hardware.

G1 & Inspire Hand Dexterity

Scaling whole-body coordination on the Unitree G1 bipedal platform with Inspire multi-finger dexterous hands, coupling locomotion policies with compliant manipulation.

Skills

Technical Arsenal

Comprehensive toolkit built through 4+ years of production robotics and computer vision deployment.

Robotics & Control

ROS/ROS2Isaac Sim / LabMoveItGazeboSim-to-RealLocomotion PoliciesSafety Layer & HALMotion PlanningTrajectory ControlSensor FusionSLAMURDF/Xacro

Platforms: Unitree G1, Inspire Hand, Pepper, UR10, NAO, Da Vinci, SCARA, AMRs, Quadrupeds

Computer Vision & AI

YOLO (v3–v11)OpenCVTensorFlowPyTorchTensorRTDeepStreamTriton InferenceObject DetectionSemantic SegmentationAnomalib

Programming

Python (Expert)C++ (Proficient)MATLABCLinux/UNIXCUDAGitDocker

Hardware & Edge

Unitree G1Inspire Dexterous HandNVIDIA Jetson XavierIndustrial Cameras3D LiDAROmron PLCArduinoIMU SensorsMulti-axis Controllers

Data & Deployment

PostgreSQLTimescaleDBKafkaMQTTDockerKubernetesREST APIsStreamlitpandasscikit-learn

Leadership

Team LeadershipProject ManagementMentorshipCross-functional CollaborationTechnical DocumentationStakeholder Communication

Concept → Deployment Pipeline

End-to-end robotics pipeline from simulation through perception, control, and production deployment.

Simulation

Isaac Sim / Gazebo / RViz

Digital twins, physics testing, synthetic data generation

Planning & Middleware

ROS/ROS2, MoveIt, Nav2

IK, trajectories, collision avoidance, SLAM

Vision & Perception

YOLO, DeepStream, TensorRT

Real-time detection, tracking, classification

Control Layer

PLC, Motor Controllers, Servos

Safety I/O, real-time control loops

Sensing

Cameras, LiDAR, IMU

Sensor fusion, calibration, data pipelines

Deployment

Jetson, Docker, Edge

Production builds, monitoring, analytics

Experience

Career Journey

From college robotics clubs to production factory floors — each role shaped how I build reliable autonomous systems.

Current Role

Senior Engineer L1

FEV India Pvt Ltd · Pune

Feb 2026 – Present

Leading humanoid robotics development focused on the Unitree G1 platform equipped with Inspire dexterous hands — architecting physics-accurate sim-to-real pipelines, locomotion policies, and mission-critical safety architectures.

Impact Delivered

  • Sim-to-Real high-fidelity physics simulations and domain-randomized workflows for robust bipedal walking and locomotion policies on the G1 platform
  • Safety Layer engineered modular safety architecture featuring 3D workspace bounding, manipulation safety constraints, and real-time hardware diagnostics
  • HAL Architecture developed Hardware Abstraction Layer (HAL) decoupling high-level policy planners from low-level actuator and sensor communication buses
  • Physical AI building egocentric multimodal data collection pipelines and synthetic data validation layers (evaluating Isaac Lab / Arena, RoboStudio, GenieSim, Lightwheel AI)
Unitree G1Inspire HandSim-to-RealLocomotion PoliciesSafety LayerHALIsaac SimPhysical AI

Senior Robotics Engineer

Wastefull Insights · Vadodara

Sep 2023 – Nov 2025

Led software architecture, perception pipeline development, and technical team coordination for autonomous robotic waste management systems.

Impact Delivered

  • 40% speed improvement by redesigning motion algorithms for 3-axis gantry, reducing inertial losses and improving cycle time precision
  • 80% computational reduction by refactoring Python to C++ for real-time processing loops
  • 91% throughput prediction using regression models on 10,000+ daily operations for data-driven optimization
  • 99.2% detection accuracy with sub-50ms latency in multi-stream video analytics pipeline
  • 30% idle time reduction through custom multi-robot coordination algorithms
PythonC++ROS2YOLODeepStreamTensorRTKafkaPostgreSQL

Robotics Engineer

Wastefull Insights · Vadodara

Aug 2022 – Sep 2023

Contributed to autonomous robotic systems for waste management, focusing on perception optimization and real-time processing.

Impact Delivered

  • 80% reduction in computational overhead by refactoring performance-critical modules from Python to C++
  • 2× faster multi-model YOLO pipeline using NVIDIA DeepStream framework for waste object tracking
PythonC++YOLODeepStreamOpenCVDocker

Jr. Robotics Engineer

Engineering Services International · Ahmedabad

Oct 2021 – Jul 2022

Developed exhibits for India's First Robotics Gallery at Gujarat Science City. Hands-on experience with 7+ diverse robotic platforms.

Impact Delivered

  • 7+ robot platforms: Pepper Humanoid, UR10, Da Vinci, SCARA, NAO, Mobile Robots, Quadruped
  • 60% development cycle reduction through Gazebo simulation workflows
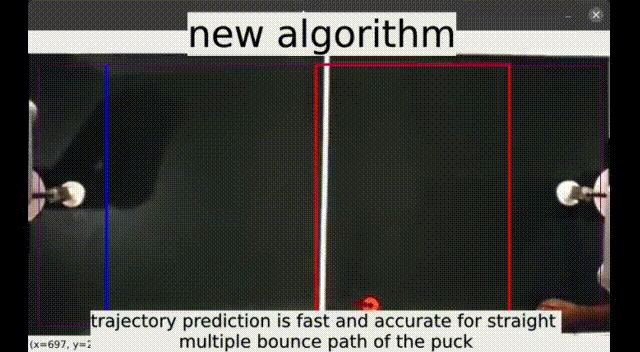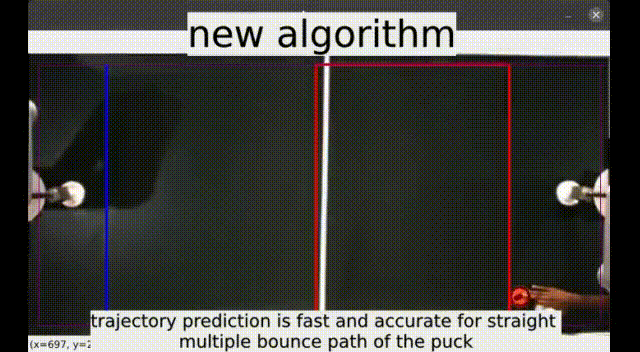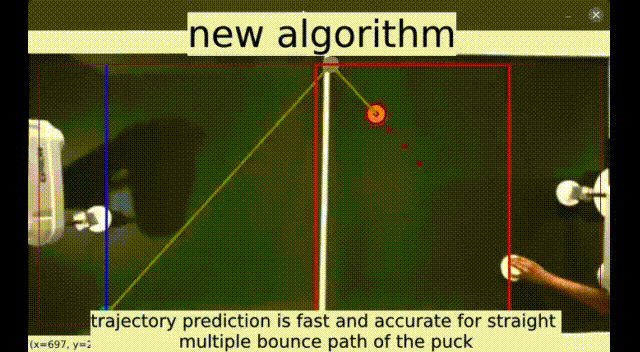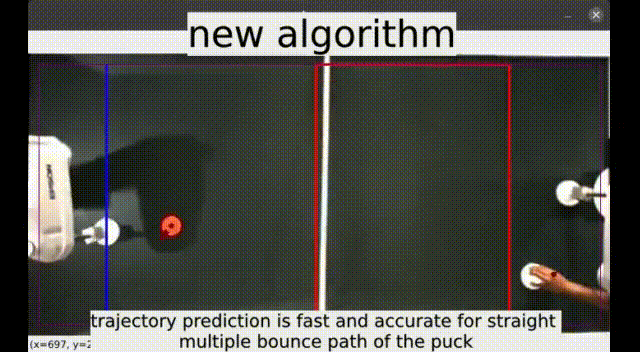
  • 240fps vision processing for air hockey robot with real-time trajectory prediction
ROSMoveItGazeboOpenCVPythonArduino

Computer Vision & ROS Intern

IN2PETA Services · Hyderabad

Jun 2021 – Oct 2021

Developed autonomous pick-and-place mobile robot for cluttered environments, integrating perception, navigation, and embedded control on NVIDIA Jetson.

Impact Delivered

  • Sub-100ms perception latency on Jetson Xavier for real-time clutter segmentation
  • 2D/3D Fusion sensor fusion combining stereo vision and 2D costmaps for dynamic collision avoidance
ROSOpenCVPythonJetson XavierSLAMNavigation

Simulation Head & Technical Mentor

RGIT's Robotics Club · Mumbai

Jul 2019 – Jun 2021

Led simulation division and mechanical/software integration for national robotics competitions. Mentored 50+ students in ROS, Gazebo, and mobile robotics.

Impact Delivered

  • 50+ engineers mentored in ROS, motion planning, and kinematics simulation
  • 2 autonomous competition platforms designed and fielded (Quadruped & 4WD Mobile Robot)
MATLABGazeboROSPythonKinematics
Engineering Portfolio

Selected Robotics Projects

Production systems, national science exhibits, and defence R&D — complete with verified problem formulations, architectures, and quantified outcomes.

Multi-Stream Video Analytics Platform
Production Deployed
Wastefull InsightsProduction Systems

Multi-Stream Video Analytics Platform

Real-time counting, tracking, and SKU classification across 4 concurrent RTSP camera feeds with 99.2% accuracy.

99.2%detection accuracy
42msinference latency
4 streamsconcurrent GPU feeds
PythonC++DeepStreamTensorRT+4
Autonomous Robotic Waste Sorting System
Production Deployed
Wastefull InsightsProduction Systems

Autonomous Robotic Waste Sorting System

End-to-end vision-guided robotic picking cell with multi-robot coordination sorting 10,000+ objects daily.

10K+daily objects sorted
80%compute overhead reduced
40%cycle speed improvement
ROS2C++PythonYOLOv8+3
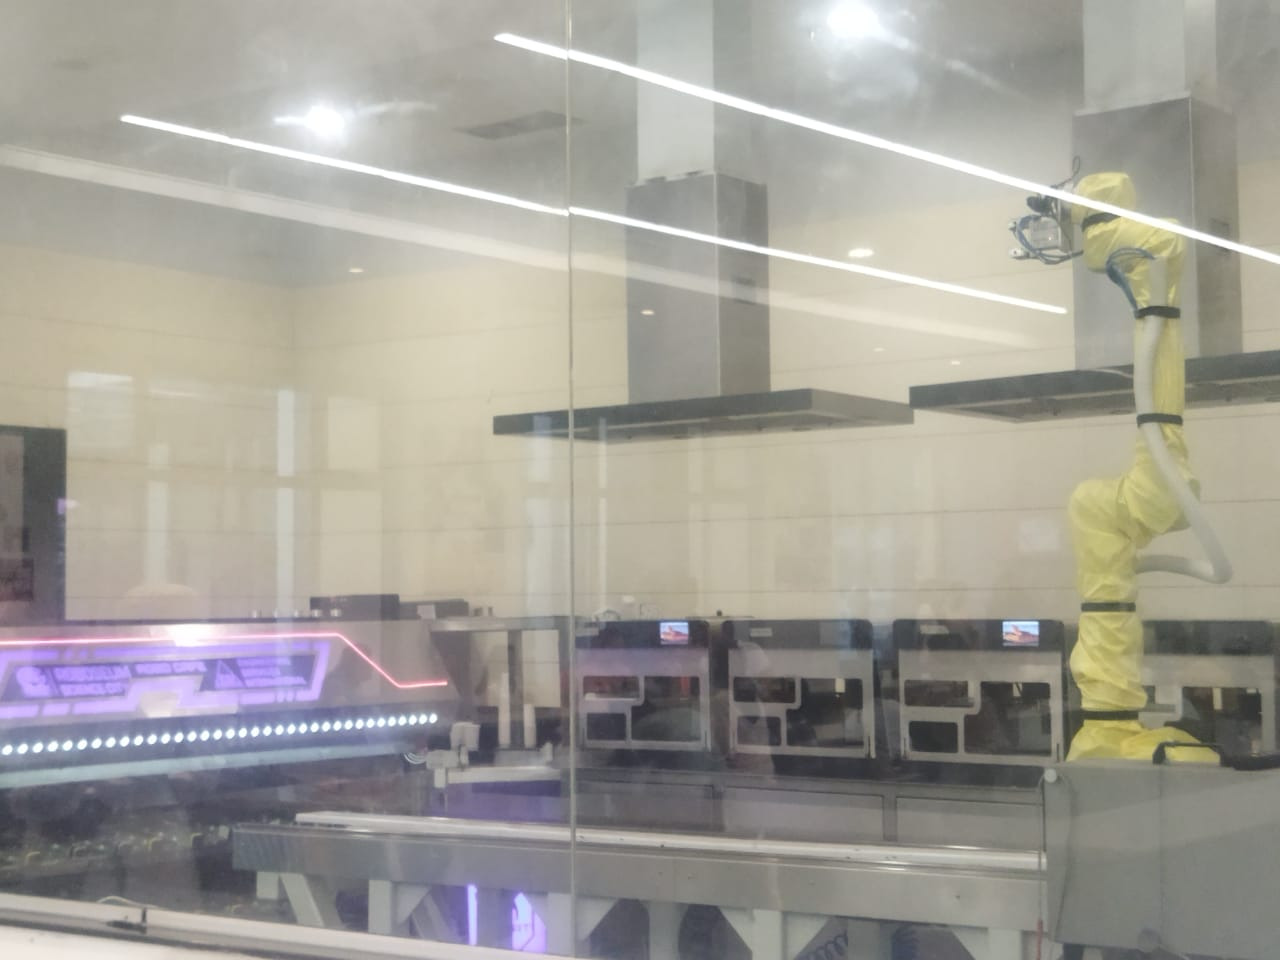
Robo Café: UR10 Automated Manipulation Cell
Production Gallery
Robotics Gallery, Science CityRobotics Gallery

Robo Café: UR10 Automated Manipulation Cell

Fully automated robotic café with UR10 manipulator on 7th-axis linear rail executing precision pick-and-place.

7-Axiscoordinated motion
60%commissioning time saved
100%collision-free operation
UR10ROSMoveItOmron PLC+3
4-DOF SCARA Air Hockey Robot with 240 FPS Vision
Production Gallery
Robotics Gallery, Science CityRobotics Gallery

4-DOF SCARA Air Hockey Robot with 240 FPS Vision

High-speed competitive robot playing real-time air hockey against human opponents with Kalman trajectory prediction.

240fpsvision processing speed
95%interception rate
<50mstotal system latency
PythonOpenCVKalman FilterSCARA Robot+2
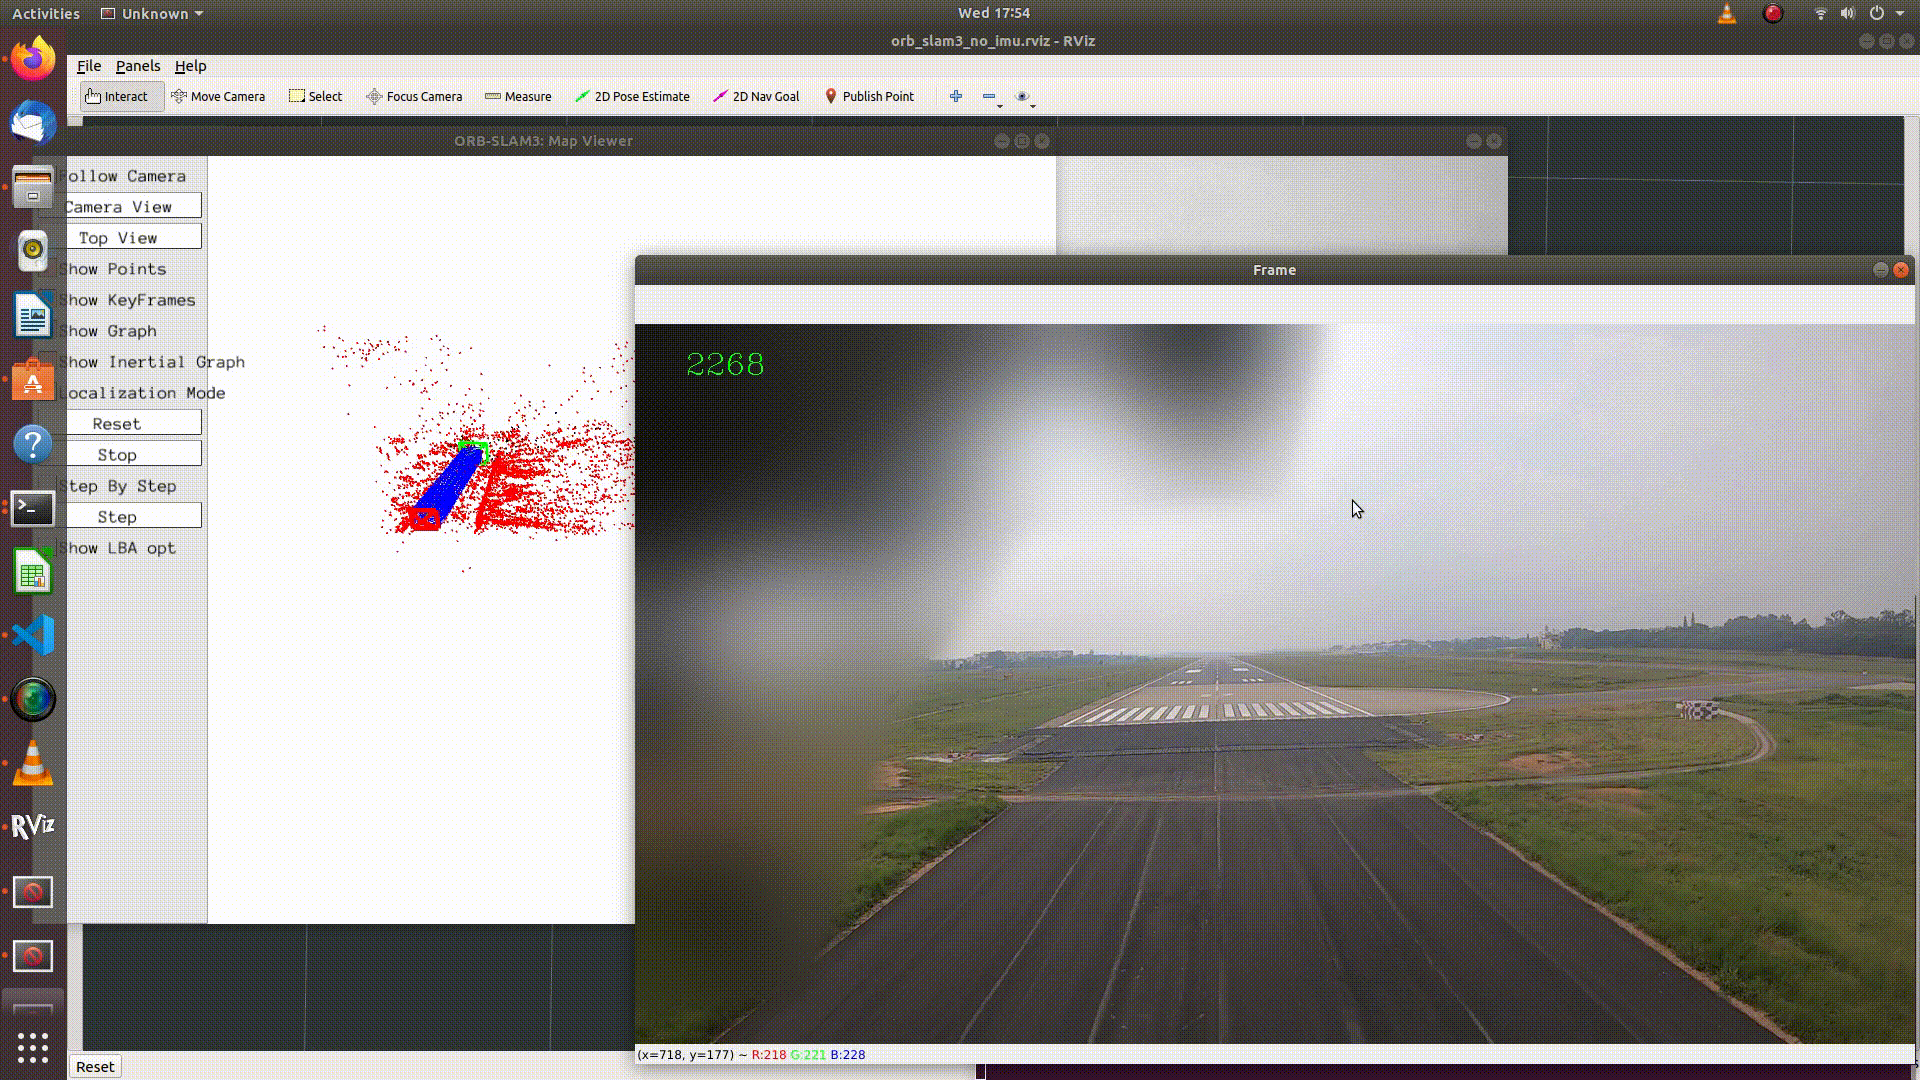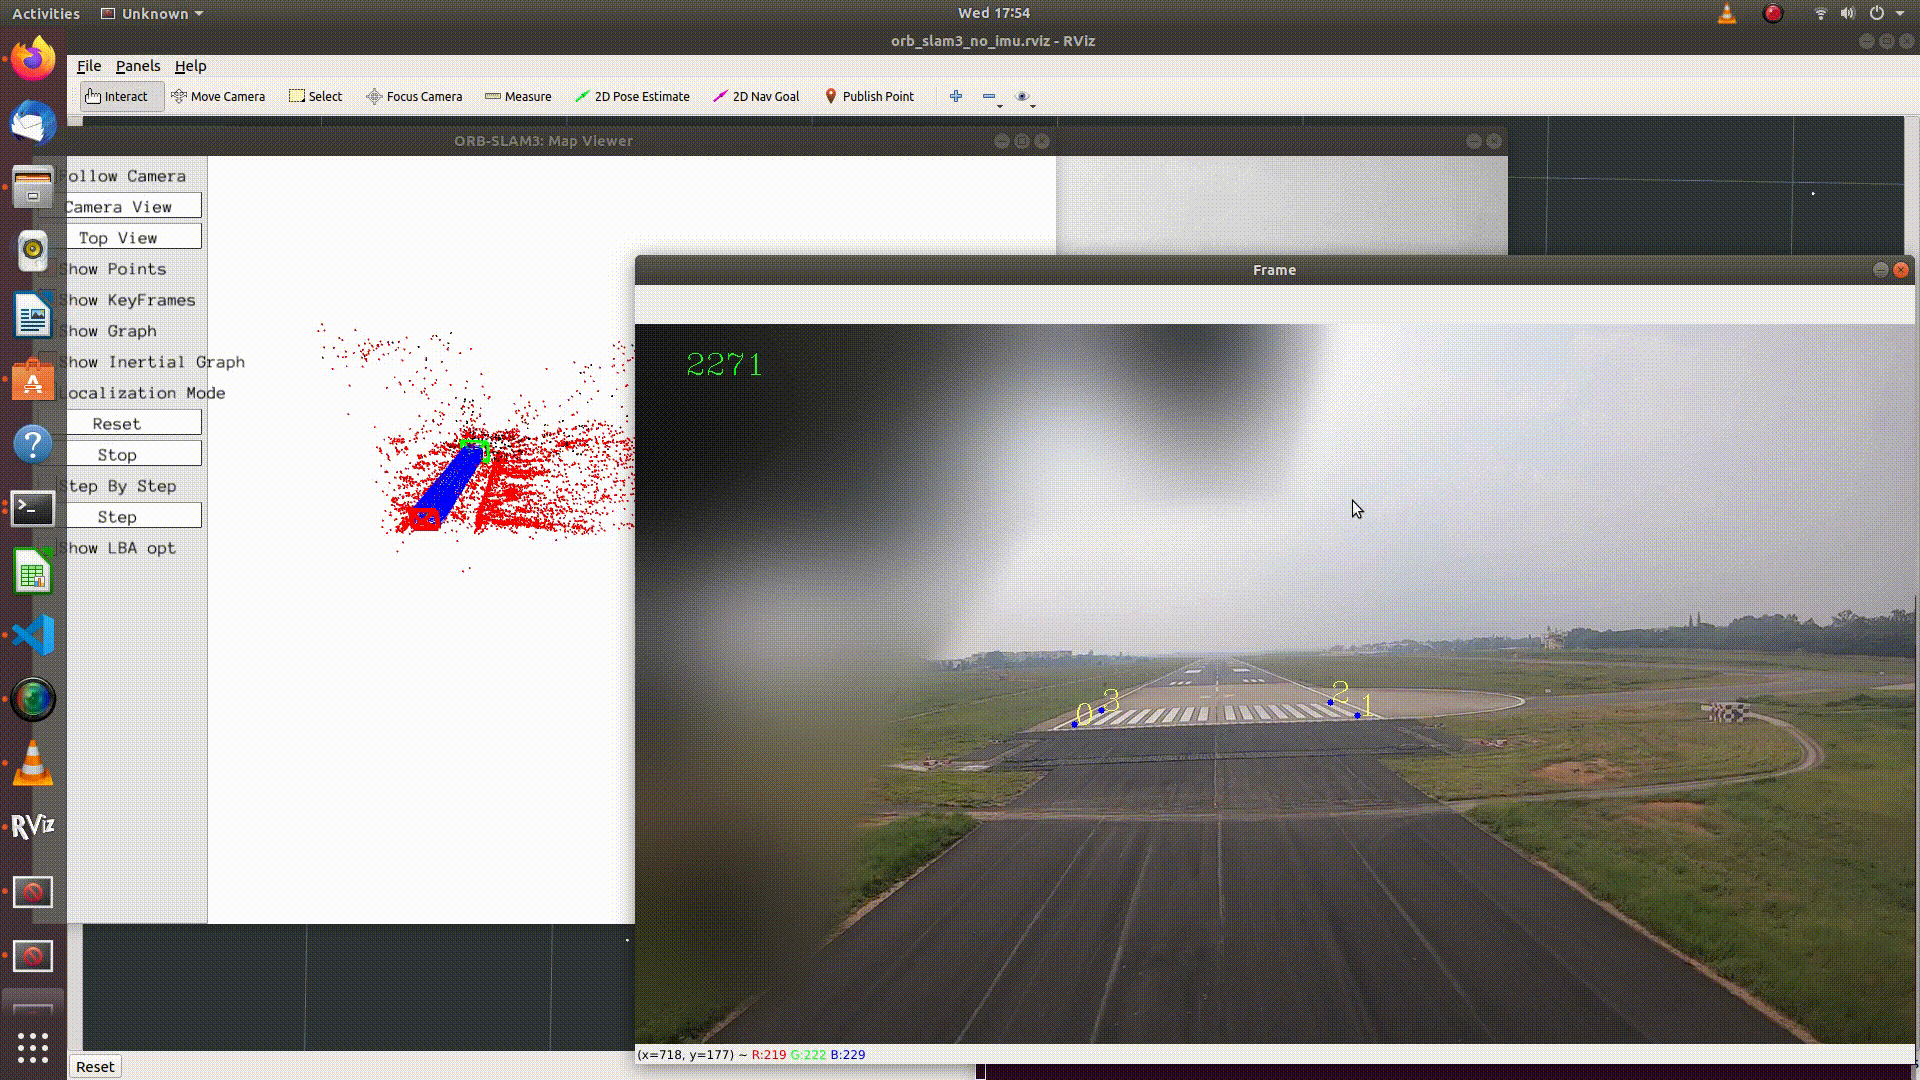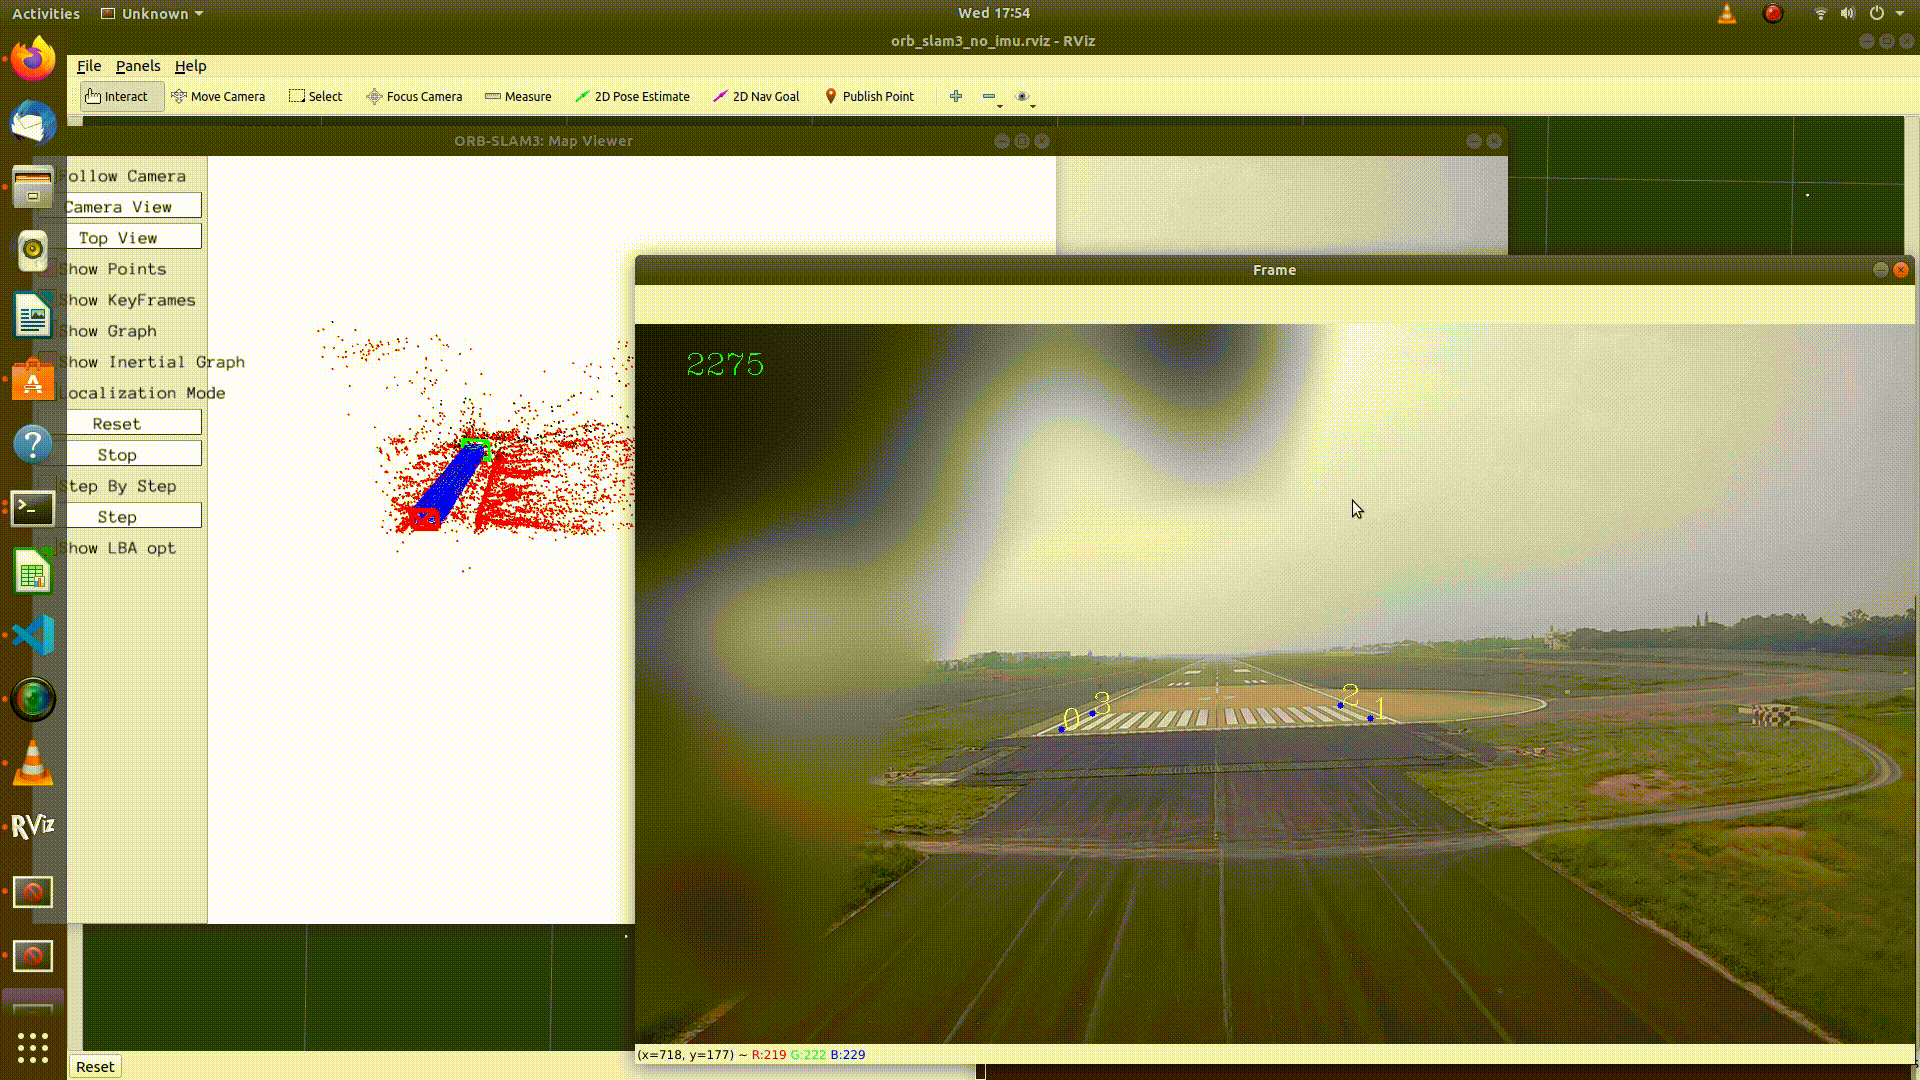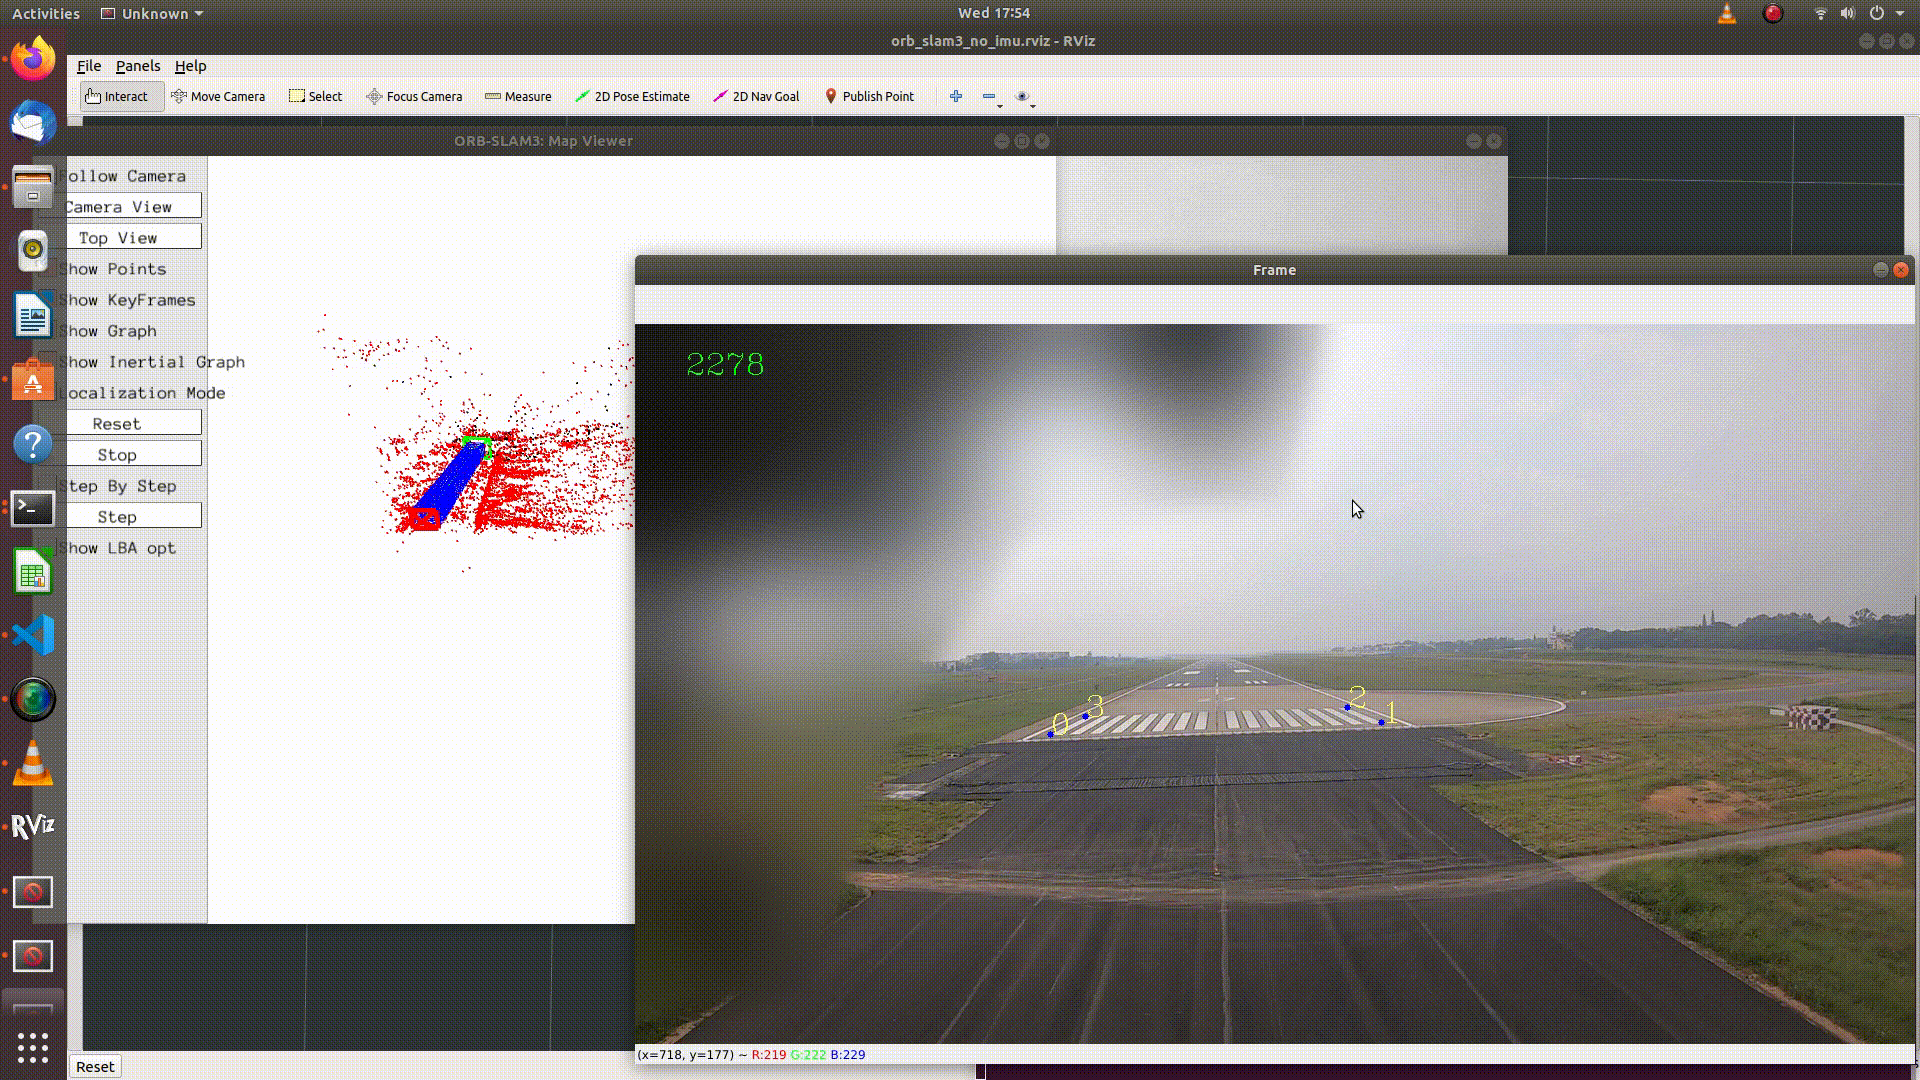
ATOL: Vision-Only 3D Position Estimation
Defence R&D
Robotics Gallery / DRDO ADAR&D

ATOL: Vision-Only 3D Position Estimation

Vision-based automated landing pose estimation system for aircraft where GPS degrades near ground level.

Vision-onlyGPS-denied navigation
6-DOFreal-time pose tracking
<10cmthreshold error margin
PythonC++ORB-SLAM3YOLOv8-Pose+3
Store Separation: 6-DOF High-Speed Pose Estimation
Defence R&D
Robotics Gallery / DRDO ADAR&D

Store Separation: 6-DOF High-Speed Pose Estimation

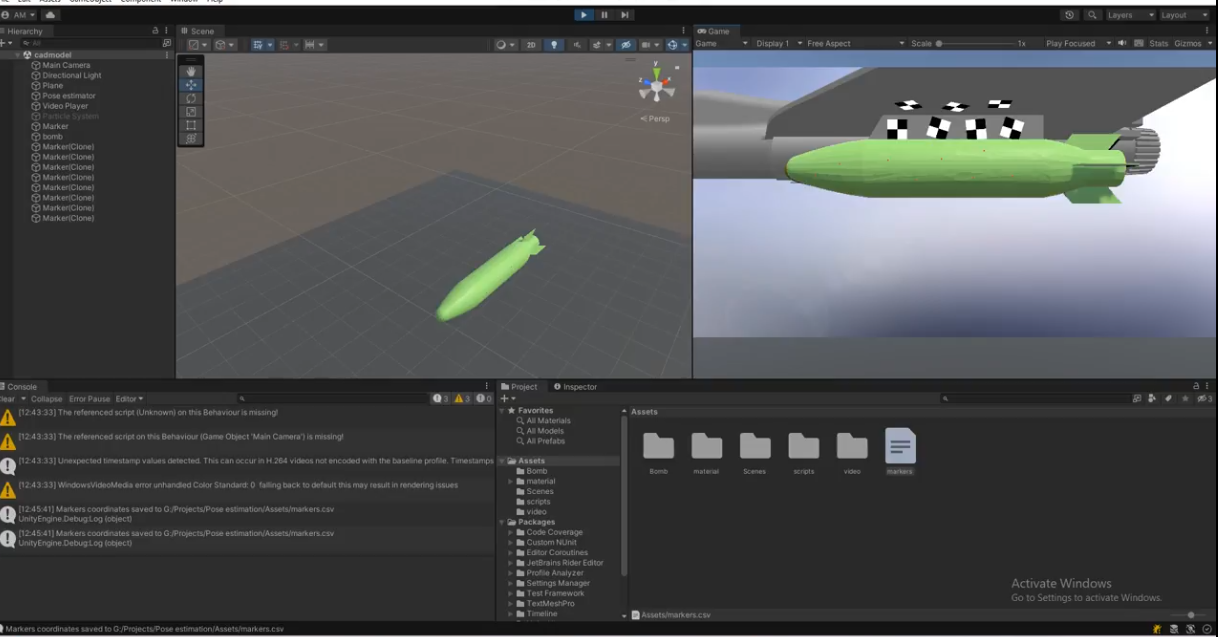
Photogrammetry algorithm recovering 6-DOF trajectory of released aircraft stores from high-speed video footage.

6-DOFmetric trajectory tracking
90%analysis time reduction
<2mmspatial accuracy limit
PythonOpenCVPnPUnity 3D+2
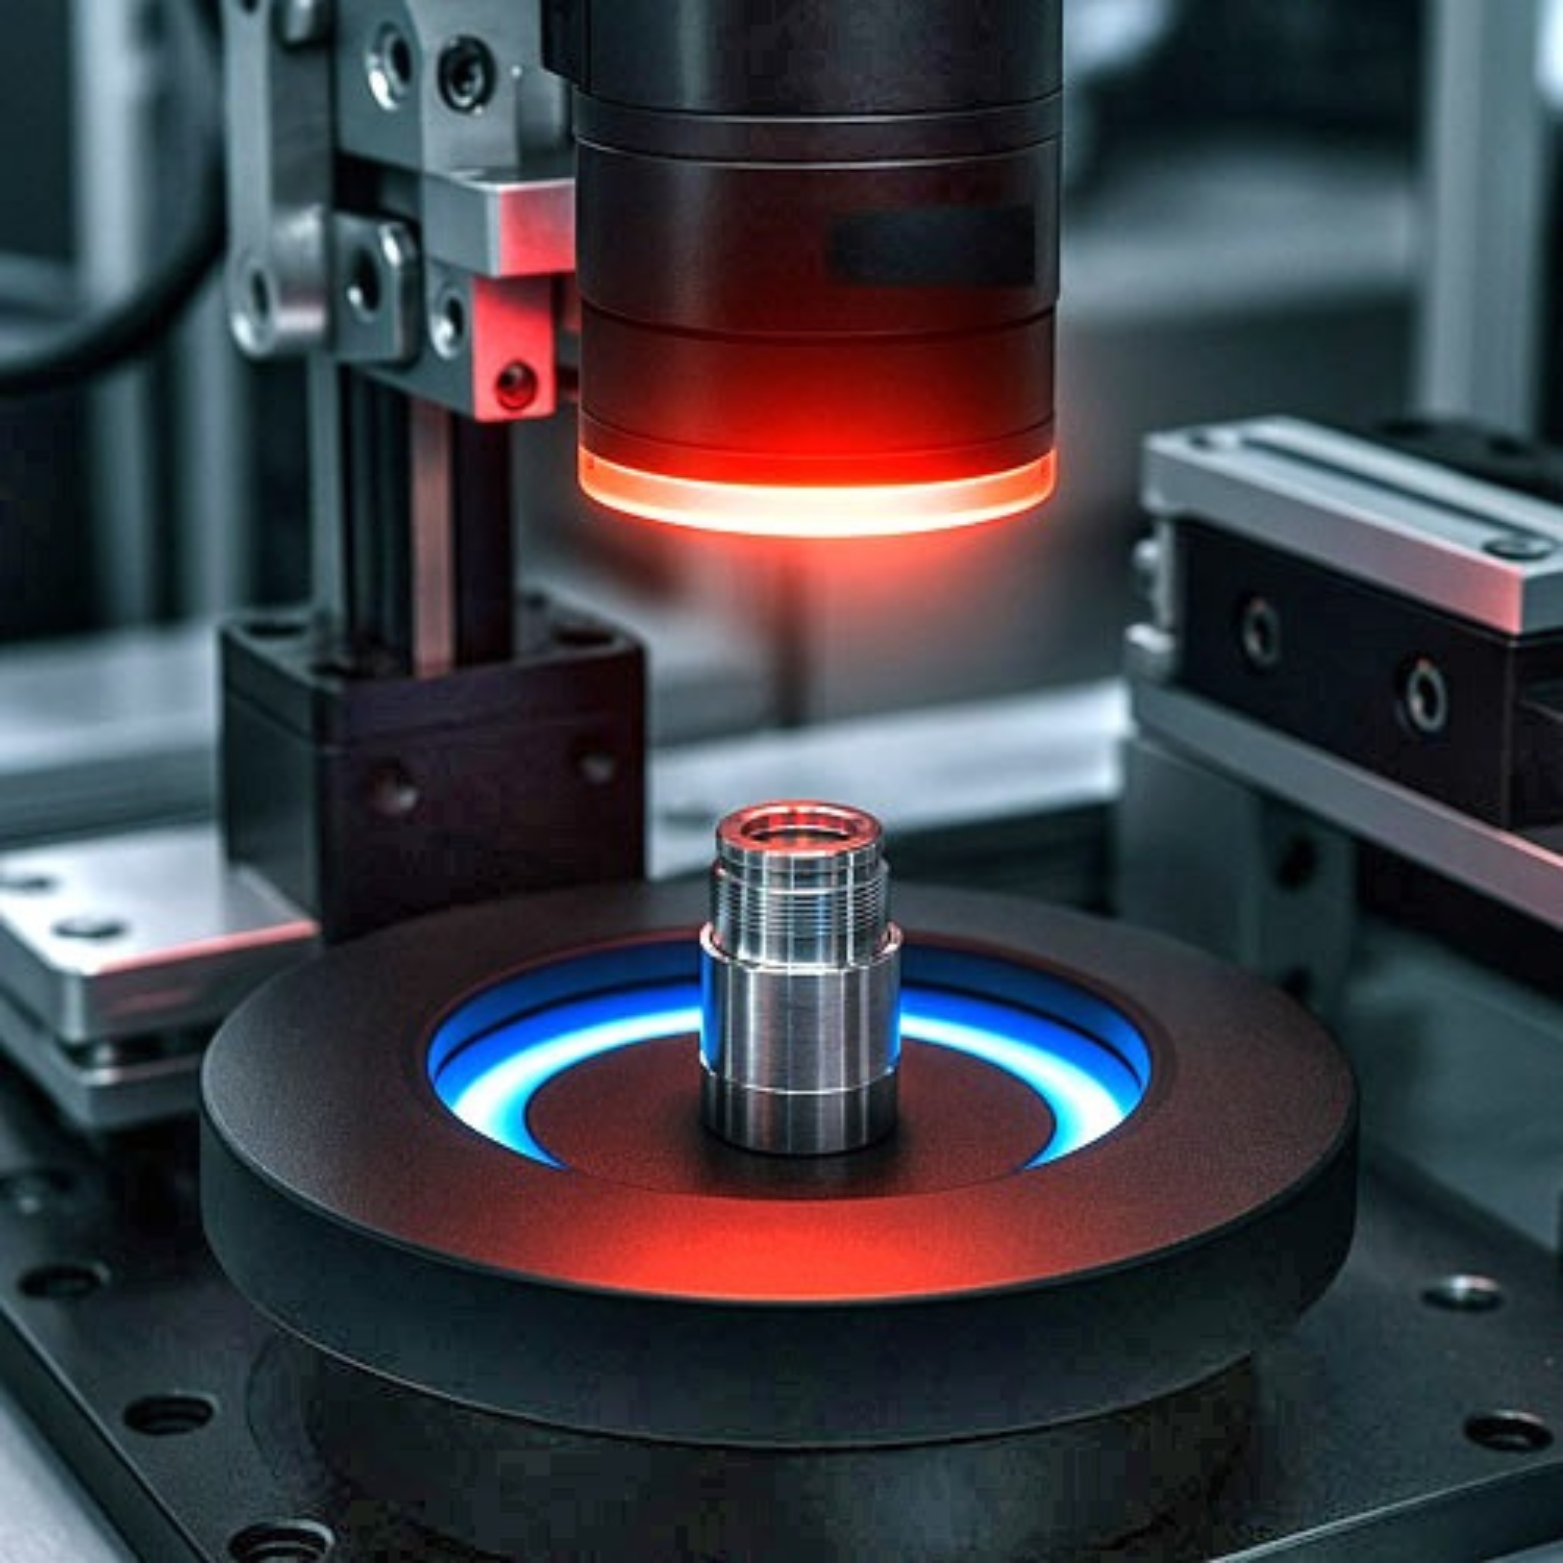
Grinding-Wheel Visual Anomaly Detection
Completed
Robotics Gallery, Science CityRobotics Gallery

Grinding-Wheel Visual Anomaly Detection

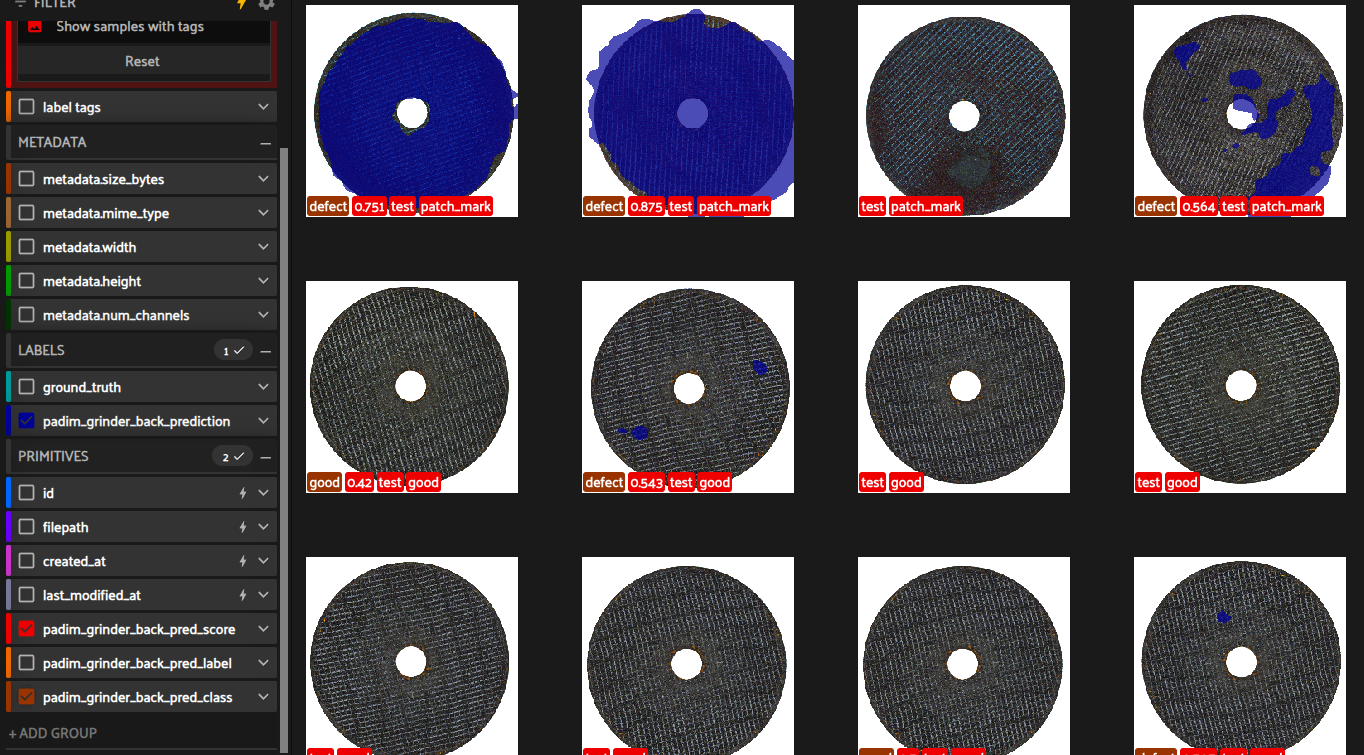
Unsupervised optical QC station flagging microscopic defects on manufactured grinding wheels using Anomalib & DeepStream.

97.4%defect detection rate
<1.8%false positive rate
Zerodefective samples needed for training
PythonAnomalibDeepStreamTensorRT+3
Pepper Humanoid Robot Exhibition Integration
Production Gallery
Robotics Gallery, Science CityRobotics Gallery

Pepper Humanoid Robot Exhibition Integration

Human-robot interaction framework with face recognition, visitor engagement, and choreographed behaviors.

500+daily visitor interactions
95%face tracking accuracy
10+autonomous behavioral modes
PythonROSNAOqi SDKOpenCV+2
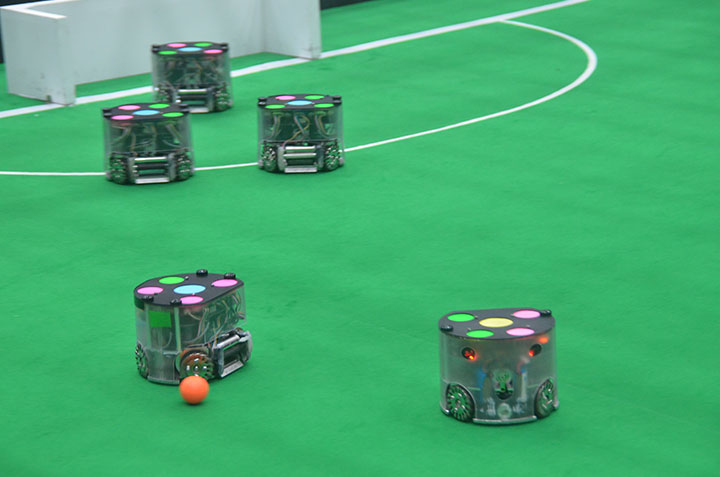
Robo Soccer: Autonomous Multi-Robot Fleet
Production Gallery
Robotics Gallery, Science CityRobotics Gallery

Robo Soccer: Autonomous Multi-Robot Fleet

Autonomous 3v3 robot soccer coordination with centralized overhead computer vision and dynamic tactical role switching.

3v3autonomous match coordination
60fpscentral vision tracking
Dynamicautonomous role reallocation
PythonROSOpenCVColor Fiducials+2
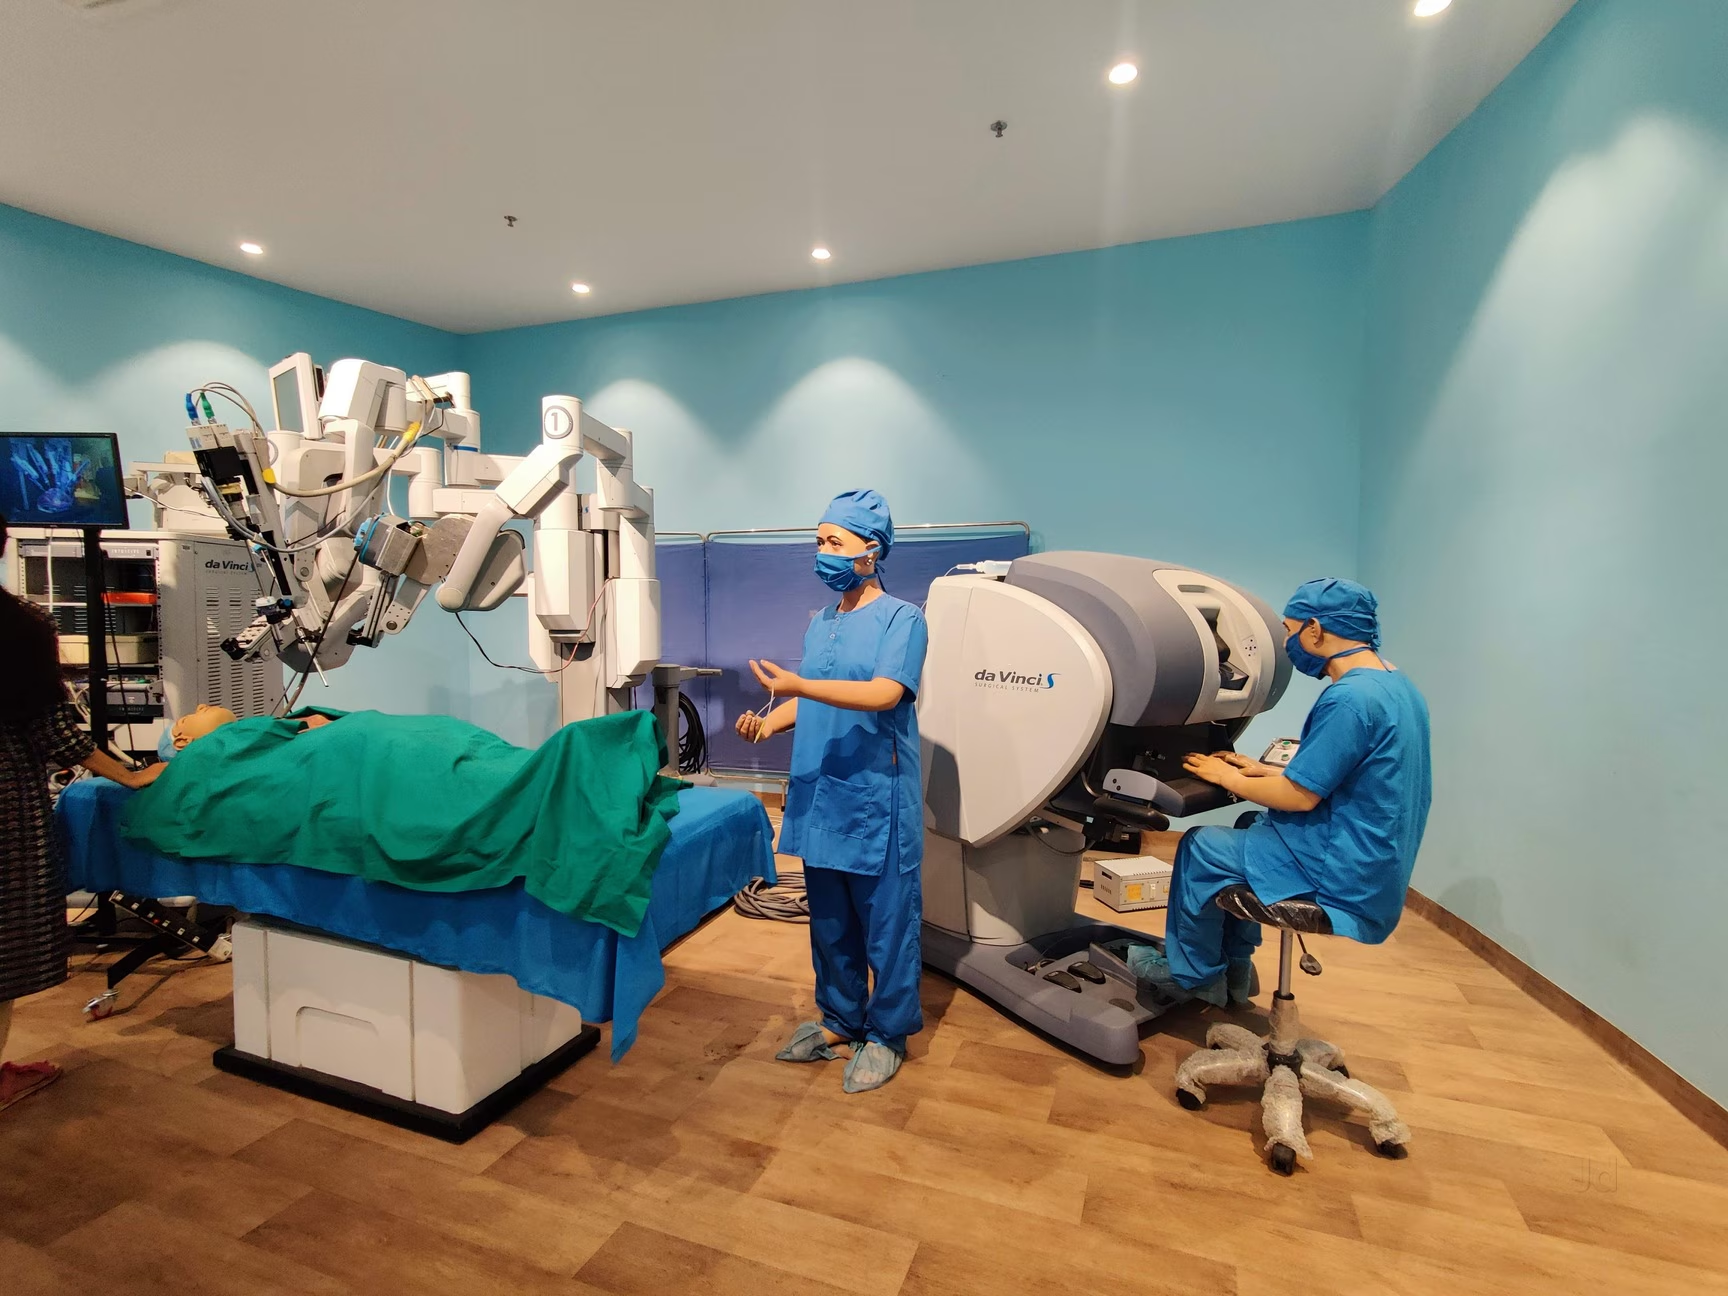
Da Vinci Surgical Robot — Gesture Teleoperation
Production Gallery
Robotics Gallery, Science CityRobotics Gallery

Da Vinci Surgical Robot — Gesture Teleoperation

Retrofitted surgical robotic arms with contactless Leap Motion gesture control for visitor demonstrations.

5 DOFhand gesture teleoperation
<100msgesture-to-motion lag
Contactlesshygienic visitor operation
ROSLeap MotionPythonC+++2
Precision Metal Component Optical QC System
Production Deployed
Industrial ManufacturingProduction Systems

Precision Metal Component Optical QC System

Automated defect inspection for precision automotive components measuring sub-100 micron geometric tolerances.

96.3%defect detection rate
3sinspection cycle time
50µmminimum defect resolution
CNNTritonPLCPython+2
Coordinated Dual-Arm Warehouse System
Award Winning
e-Yantra National Robotics CompetitionR&D

Coordinated Dual-Arm Warehouse System

Dual UR5 robot arms coordinated via MQTT for autonomous warehouse sorting, packaging, and order dispatching.

Zerodual-arm collisions
100%order fulfillment accuracy
2 Armssynchronized parallel execution
ROSMoveItGazeboMQTT+2

Services

What I Offer

Professional consulting and development services for robotics, computer vision, and industrial automation.

Robotics Engineering Consulting

End-to-end design and development of autonomous robotic systems for industrial applications — motion planning, control systems, hardware integration, and production deployment.

Computer Vision & AI Solutions

Custom vision systems, object detection, segmentation, and AI/ML deployment on edge devices. From training pipelines to TensorRT-optimized production inference.

Digital Twin Development

Virtual representations of physical systems for simulation, testing, and optimization. Sim-to-real transfer techniques for seamless virtual-to-physical deployment.

Technical Workshops & Training

Hands-on robotics and computer vision workshops for students, professionals, and organizations. Topics include ROS, computer vision, and embedded systems.

Mentorship & Code Reviews

One-on-one mentorship for robotics projects, code reviews, and guidance on best practices in autonomous systems development.

Conference Speaking

Technical presentations at robotics conferences sharing insights on production-grade vision systems and AI-accelerated development.

Open-Source Collaboration

Collaboration on open-source robotics projects, code contributions, and community-driven initiatives to advance robotics technology.

Engineering Deep Dives

Field notes, profiling breakdowns, and architectural post-mortems from production robotics deployments, bipedal humanoid locomotion, and edge AI vision.

Contact

Let's Connect

I'm always excited to connect with fellow engineers, researchers, and innovators. Whether you have questions about robotics, want to discuss potential collaborations, or just want to say hello — I'd love to hear from you!

Location

Mumbai, IndiaOpen to global opportunities

Send a Message